SPI Engine Execution Module
The SPI Engine Execution IP core is the heart of the SPI Engine framework. It is responsible for handling a SPI Engine control stream and translates it into low-level SPI bus transactions.
Files
Name |
Description |
|---|---|
library/spi_engine/spi_engine_execution/spi_engine_execution.v |
Verilog source for the peripheral. |
library/spi_engine/spi_engine_execution/spi_engine_execution_ip.tcl |
TCL script to generate the Vivado IP-integrator project for the peripheral. |
Configuration Parameters
Name |
Description |
|---|---|
NUM_OF_CS |
Number of chip-select signals for the SPI bus (min: 1, max: 8). |
DEFAULT_SPI_CFG |
Reset configuration value for the SPI Configuration Register |
DEFAULT_CLK_DIV |
Reset configuration value for the Prescaler Configuration Register |
DATA_WIDTH |
Data width of the parallel data stream. Will define the transaction’s granularity. Supported values: 8/16/24/32 |
NUM_OF_SDI |
Number of multiple SDI lines, (min: 1, max: 8) |
Signal and Interface Pins
Name |
Description |
|---|---|
clk |
All other signals are synchronous to this clock. |
resetn |
Resets the internal state machine of the core. |
ctrl |
SPI Engine Control Interface subordinate. SPI Engine Control stream that contains commands and data for the execution module. |
spi |
SPI Bus Interface controller. Low-level SPI bus interface that is controlled by peripheral. |
Theory of Operation
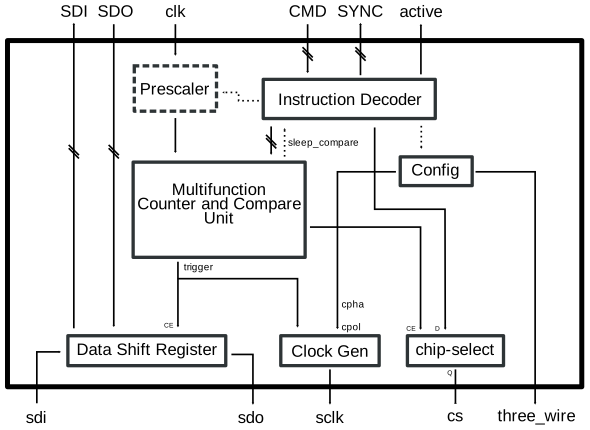
The SPI Engine Execution module implements the physical access to the SPI bus. It implements a small but powerful programmable state machine that translates a SPI Engine command stream into low-level SPI bus access.
Communication with a command stream generator happens via the ctrl
interface and the low-level SPI access is handled on the spi interface.
Internally the SPI Engine execution module consists of an instruction encoder that translates the incoming commands into an internal control signal, a multi-function counter and compares unit that is responsible for handling the timing and a shift register which holds the received and transmitted SPI data.
The module has an optional programmable pre-scaler register that can be used to divide the external clock to the counter and compare unit.