Robotics SDK
Kickstart your robotics development with Analog Devices robotics SDK (Software Development Kit)
These modules, reference designs, and development platforms combine the necessary technologies, tools, and software for rapid system integration of ROS 2 elements in industrial applications.
Quick Start
How It Works
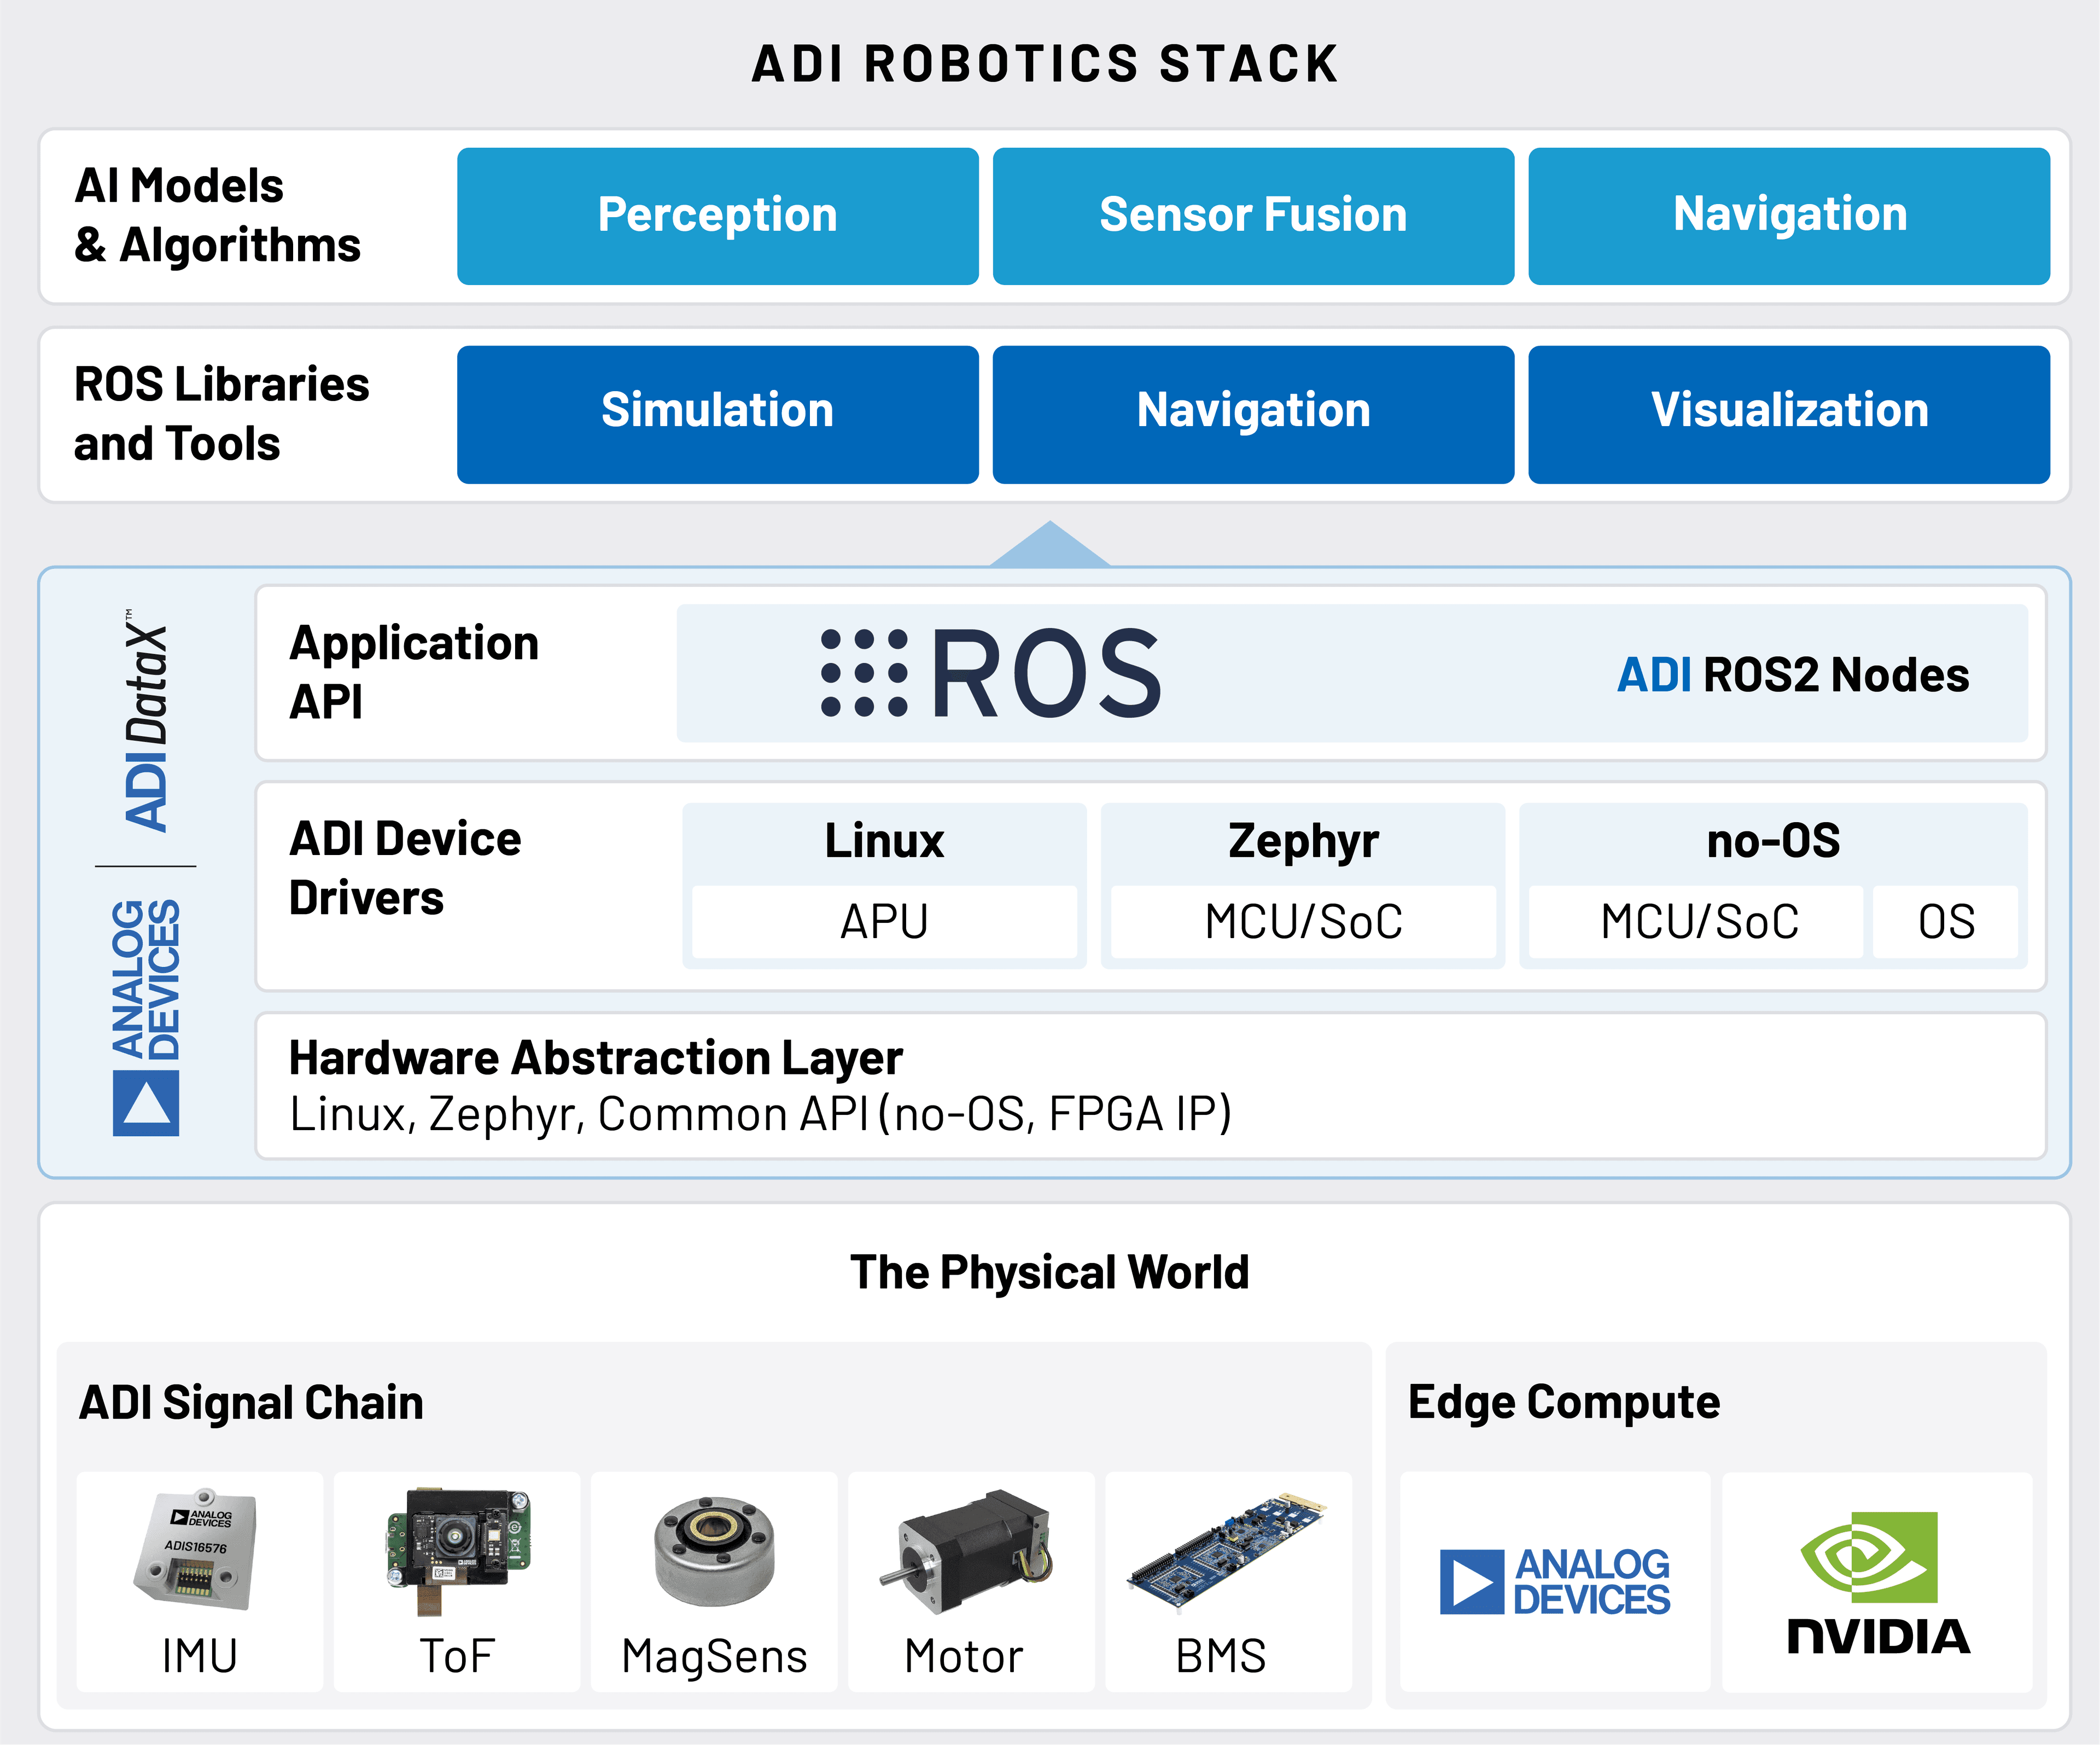
The Analog Devices Robotics SDK provides a collection of ROS 2 packages and 3rd party tools for robotics applications. The ADI ROS 2 Github Repository aggregates various ADI ROS 2 packages into pre-configured Docker containers, offering a ready-to-use environment for diverse compute platforms.
Learn how to build scalable autonomous mobile robots (AMR) using open-source hardware and software robotics solutions from ADI. Key design considerations include modularity, interoperability, and standardized software interfaces exposed through ROS 2 nodes.
Getting Started
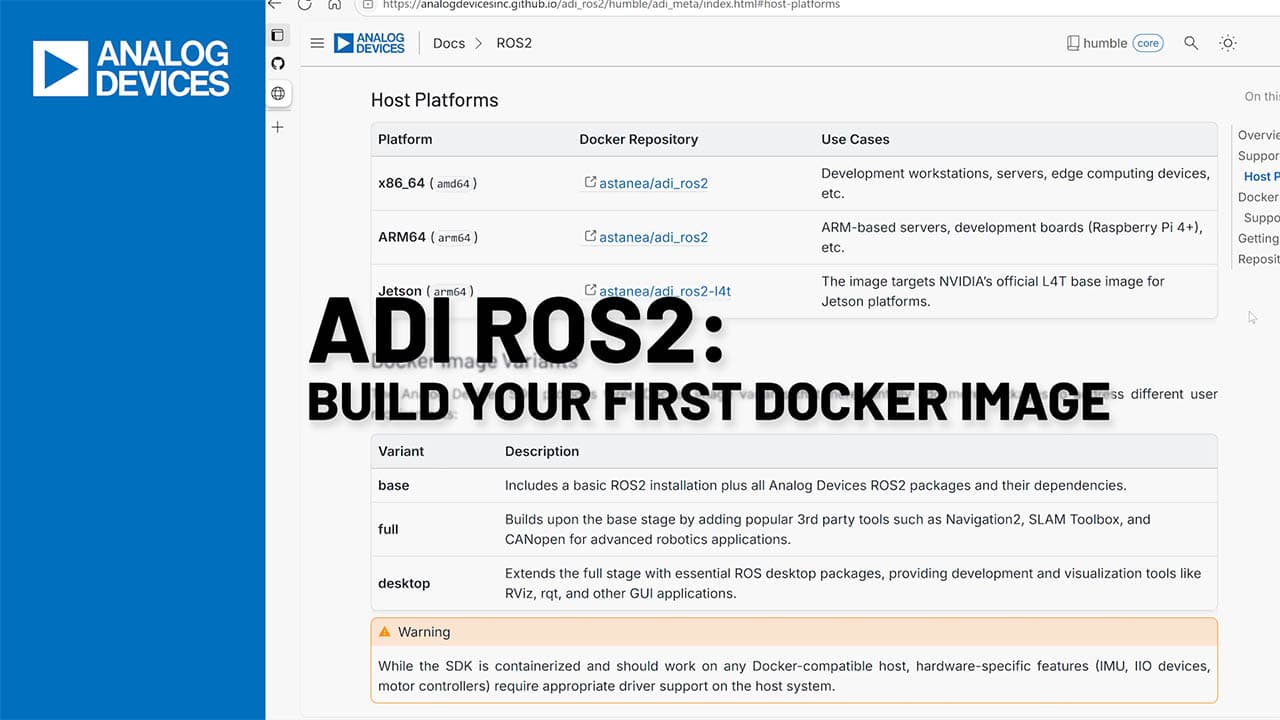
Set up quickly with ADI’s ROS 2 SDK and start building intelligent robotics applications today. Follow step-by-step instructions to install dependencies, configure your environment, and launch example nodes.
Tutorials
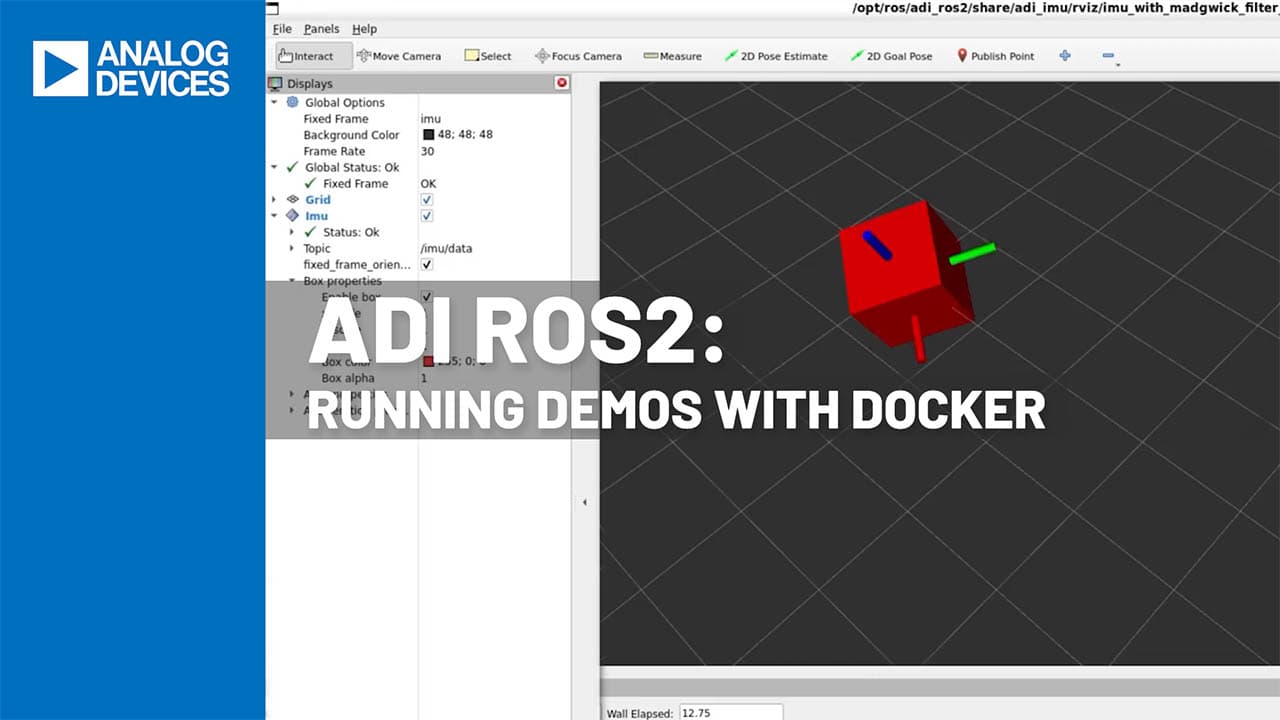
Key Features
Out-of-the-Box Development Environment
- Provides a pre-configured, ready-to-use development environment with all essential ROS 2 and ADI packages.
- Enables immediate application development without manual dependency installation or complex environmental setups.
Broad Hardware and Platform Compatibility
- Ensures extensive compatibility with various hardware architectures and seamless deployment across diverse robotics platforms.
- Multi-Architecture Support: Compatible with NVIDIA Jetson, ARM64 and x86_64 architectures.
- Modular Docker Variants: Offers base, full, and desktop Docker image variants to cater to specific development needs and resource availability.
Accelerated Integration and Prototyping
- Minimal Configuration: Simplifies the process of integrating ADI hardware into ROS 2 systems, requiring minimal manual configuration.
- Streamlined Hardware Enablement: Leverages pre-built Docker images with ADI packages for rapid component integration.
- Focus on Application Logic: Frees developers from complex setup procedures, shifting focus towards innovation and core application development.
Reference System: AD-R1M Autonomous Mobile Robot
Analog Devices AD-R1M, is a modular open-source Autonomous Mobile Robot (AMR) reference design that shows how developers can build a complete robotics system with the ADI Robotics SDK, from integrating sensors and motion control to enabling ROS2-based autonomy.
As a working robotics application, It brings ADI hardware, software, and tools together in a complete robotics system, while aligning to the broader ADI DataX™ ecosystem, enabling consistent data handling and interoperability across sensing, compute, and application layers.
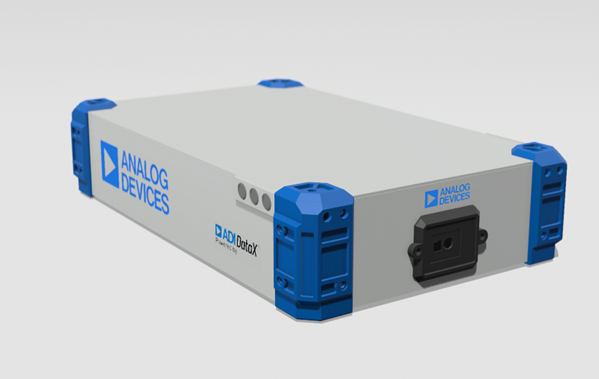
AMR Concept Design
From Components to a Complete Robotics System
The AD-R1M gives a blueprint for turning ADI components into a functional robotics system, combining hardware, ROS2 software, data pipelines, and deployment guidance in one modular reference design:
- Integration of ADI ROS2 packages into a full autonomy stack (sensing, localization, navigation)
- End-to-end data flow from sensors and motion control to navigation and decision-making
- Alignment of robotics data pipelines with the ADI DataX™ framework for cross-platform interoperability.
- Mapping of hardware components to ROS2 nodes and standardized interfaces
- Deployment across different compute platforms (e.g., Raspberry Pi or Jetson)
- A modular and extensible system architec-ure for robotics applications
Full list of AD-R1M Components
Start Building with AD‑R1M
Explore the AD‑R1M documentation and tutorials to learn how the platform is built, deployed, and extended from system architecture and data flow to ROS2 nodes, software components, and example applications.
Use these resources to understand how AD‑R1M brings together hardware, software, and deployment guidance in a practical robotics reference system.
Key Features
AD‑R1M demonstrates how the reference design can support practical robotics workloads across mapping, navigation, perception, localization, and fleet-level coordination.
- Mapping and navigation: SLAM, mapping, and autonomous navigation workflows. (Learn More)
- Localization: GPU-accelerated localization using approaches such as NVIDIA cuVSLAM. (Learn More)
- Perception: Pipelines such as floor segmentation and object detection.
- Fleet coordination: Multi-robot coordination scenarios that extend beyond a single AMR.
The complete ROS2 packages and AD‑R1M system implementation are available as open source, giving developers access to the full software stack so they can evaluate, customize, and extend the platform.
ADI ROS 2 Compatible Hardware
- ADI ROS 2 ToF - ADTF3175 - 1 MegaPixel Time-of-Flight Module
- ADI ROS 2 IMU - Supported Devices
- ADI ROS 2 Motor Control - Supported TMC boards
Related Resources
Comments
Join the conversation at EngineerZone