blog
August 28, 2026
Industrial Dexterity Benchmark: learned policies for contact-rich assembly
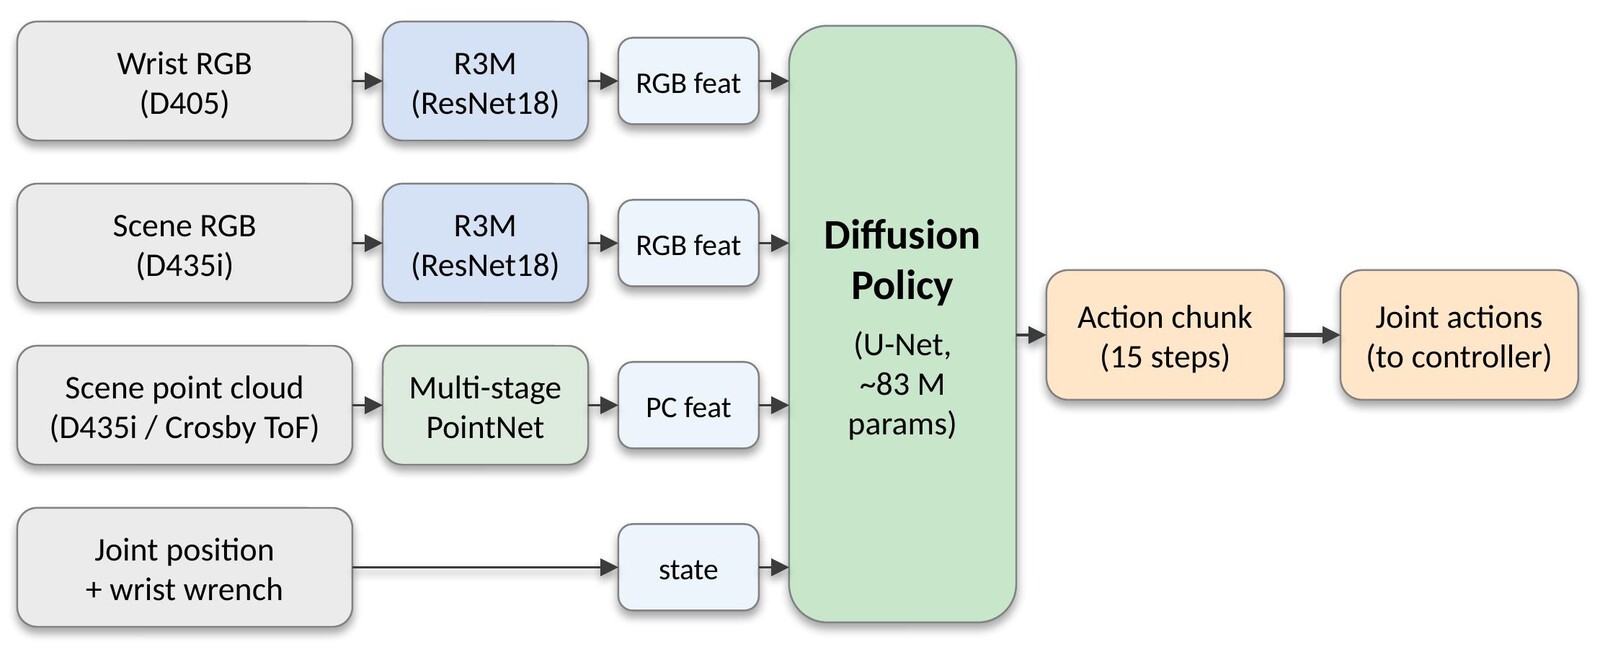
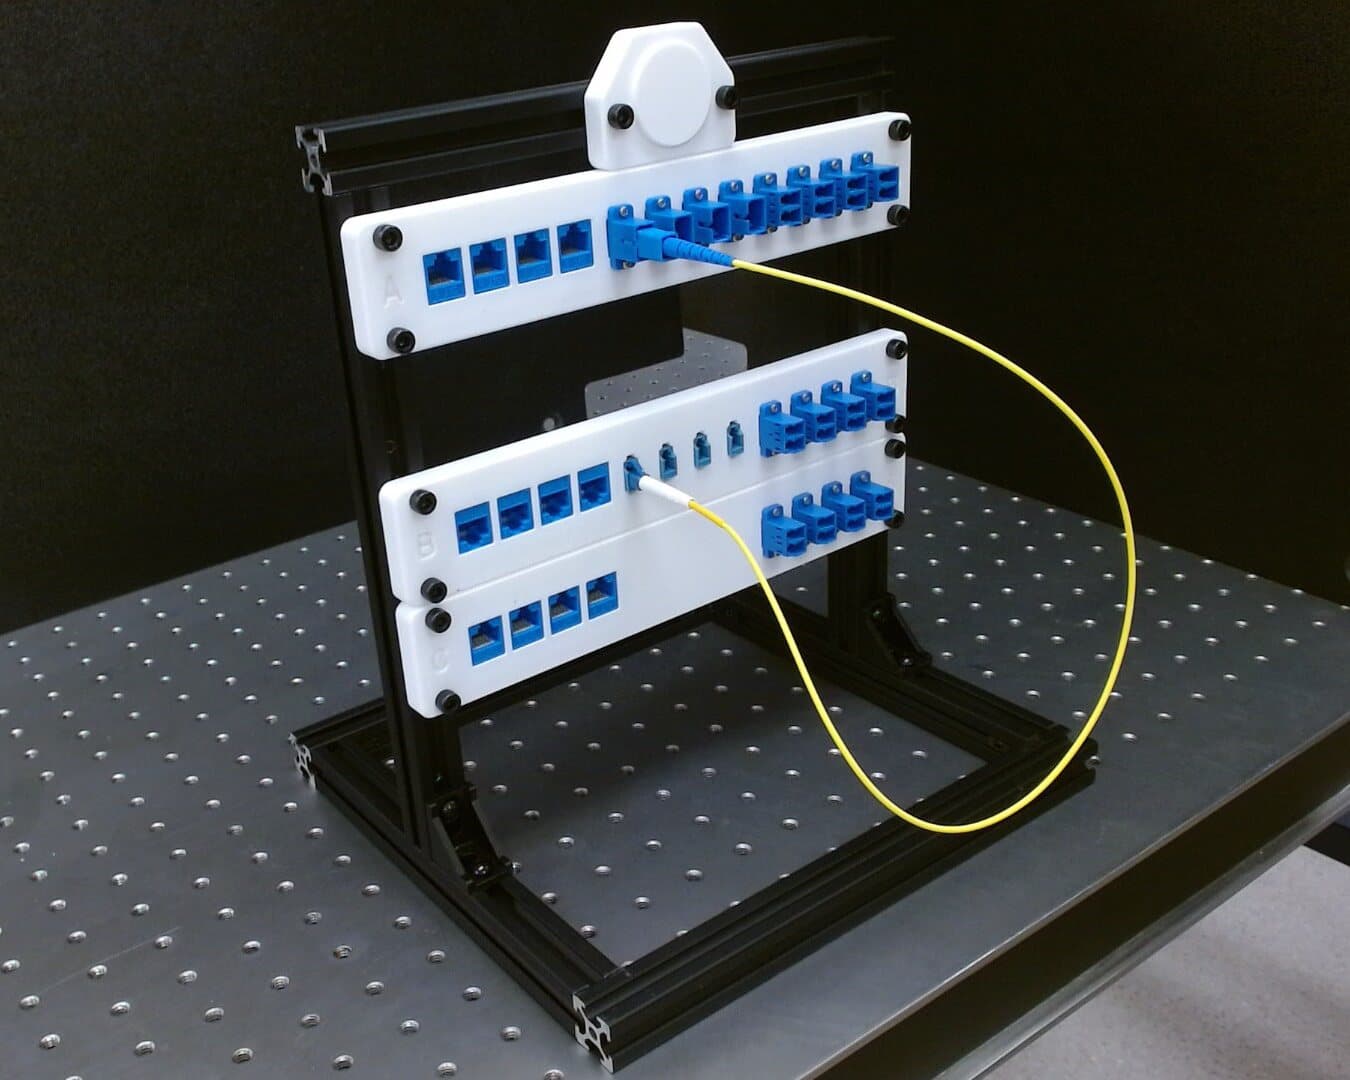
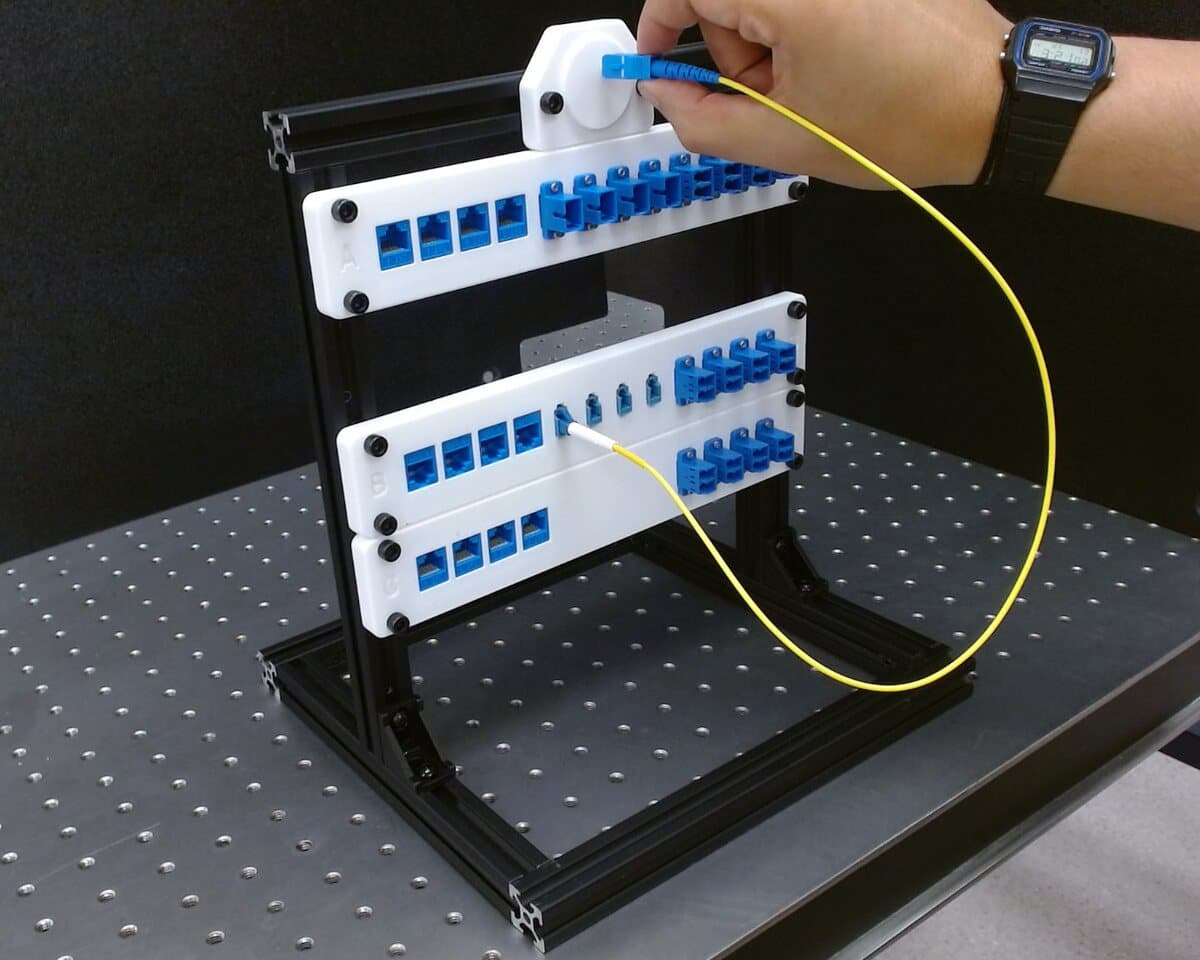
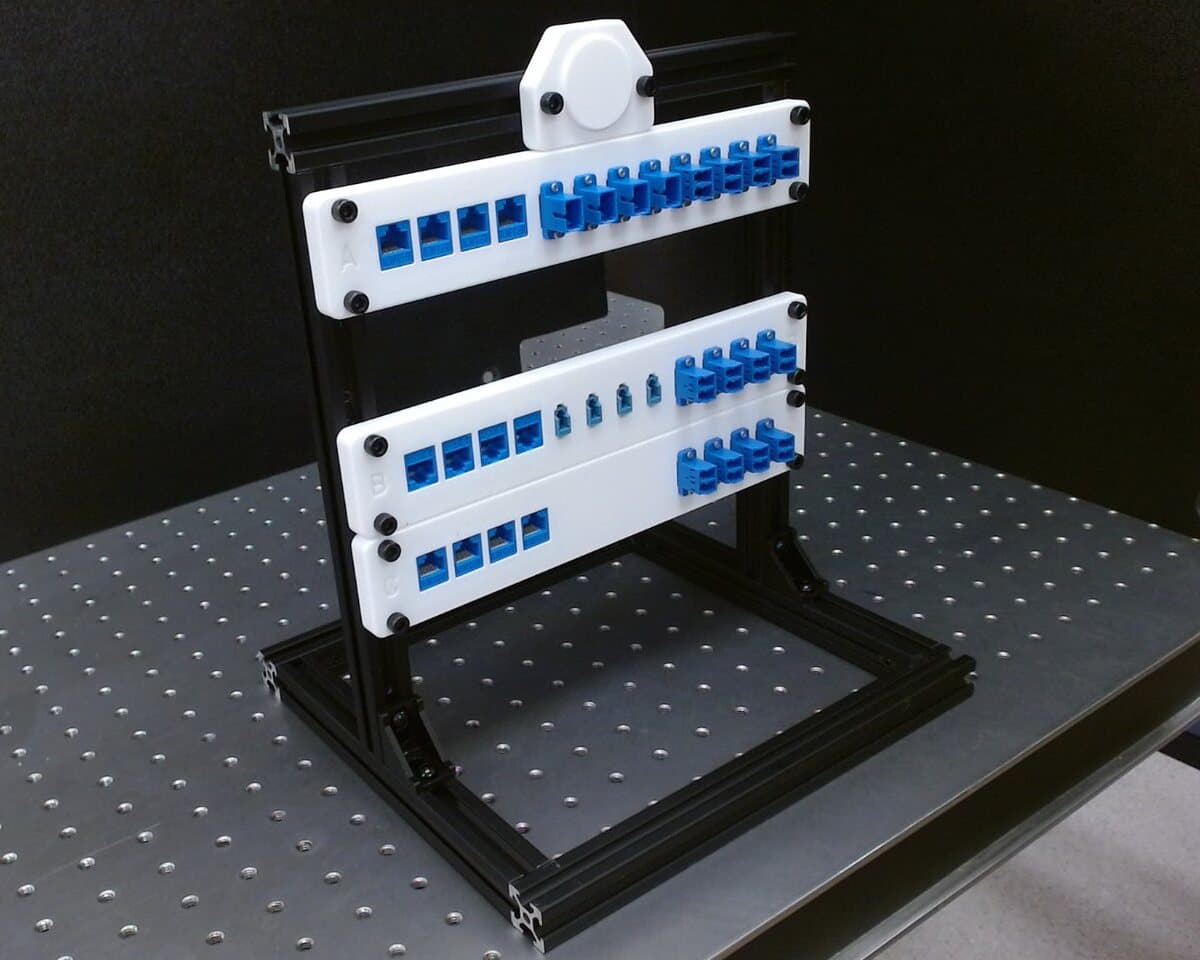
A hardware–software platform for industrial dexterous manipulation — three open benchmark boards, a scalable imitation-learning stack, and a multimodal diffusion policy that fuses RGB, point clouds, and force.

Authors:
Honglu He†, Jacob Laufer†, Zhiwu Zheng, David Elkan-Gonzalez, Raman Goyal, Xinyi Li, Su Lu, Mishek Musa, Berke Saat, Nicolas Tan, Colm Prendergast
†equal contribution
Three Contributions
Benchmark boards, a data engine, and a multimodal policy
A complete loop from physical task design, through scalable demonstration collection, to a policy that fuses everything the robot can sense.
01 / Industrial Dexterity Benchmark | 02 / DAG-ROS | 03 / AG-iDP3 |
|---|---|---|
Benchmark boards | Imitation-learning stack | Multimodal diffusion policy |
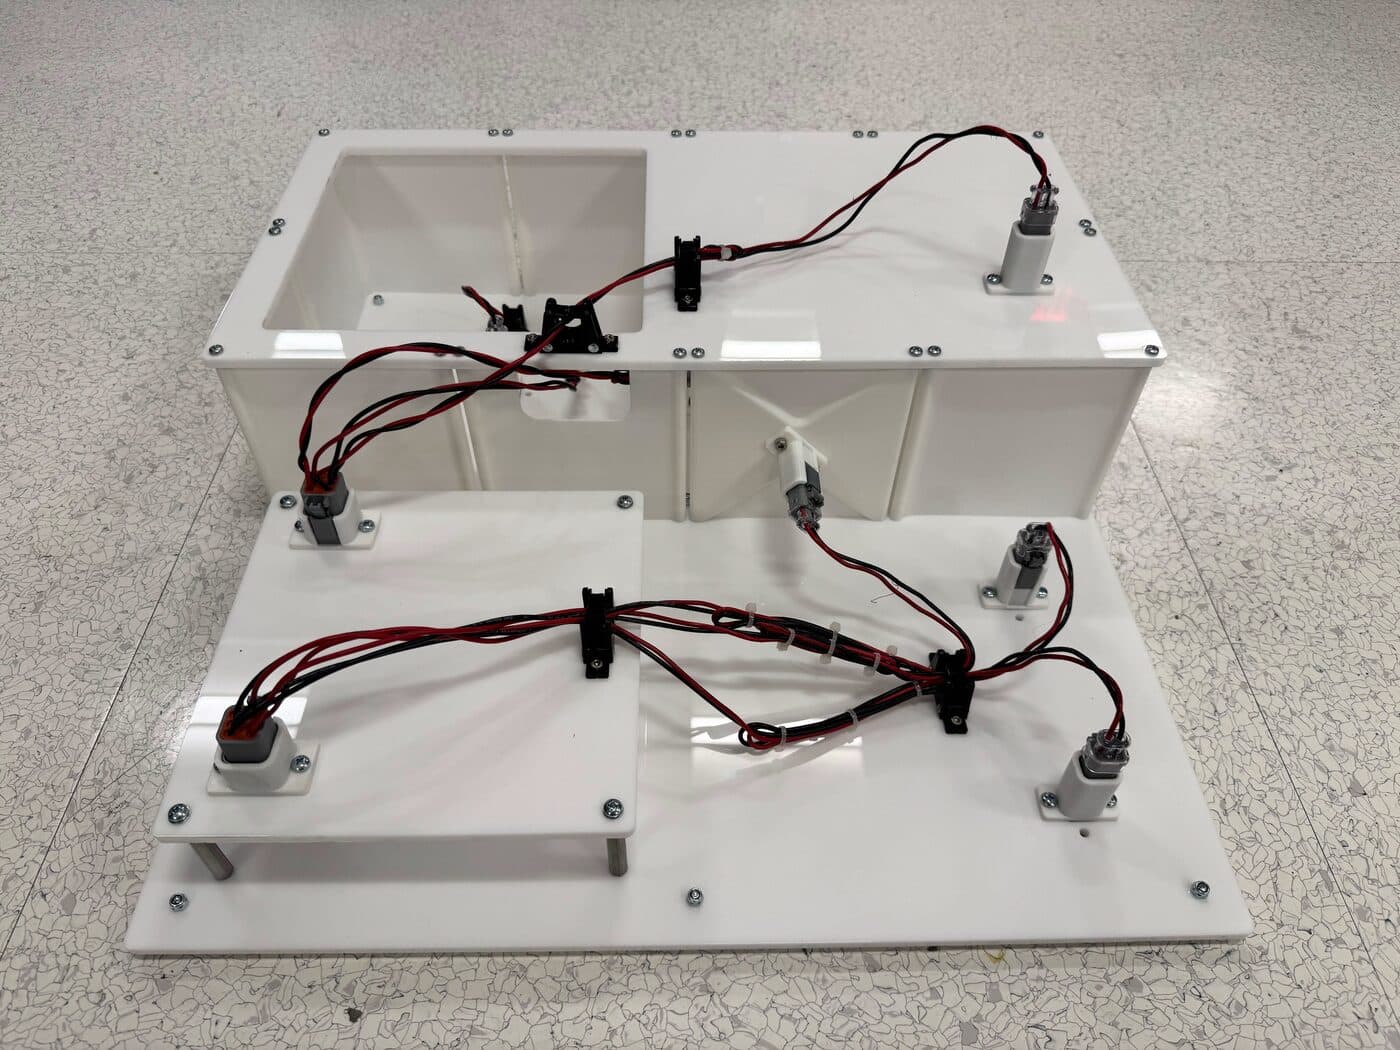
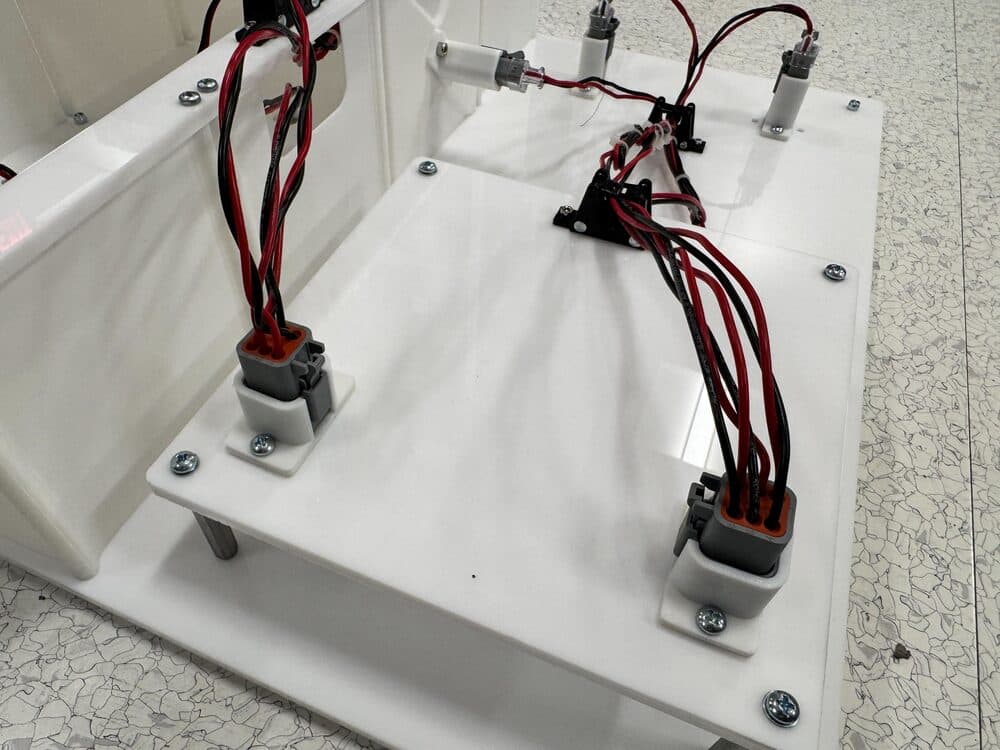
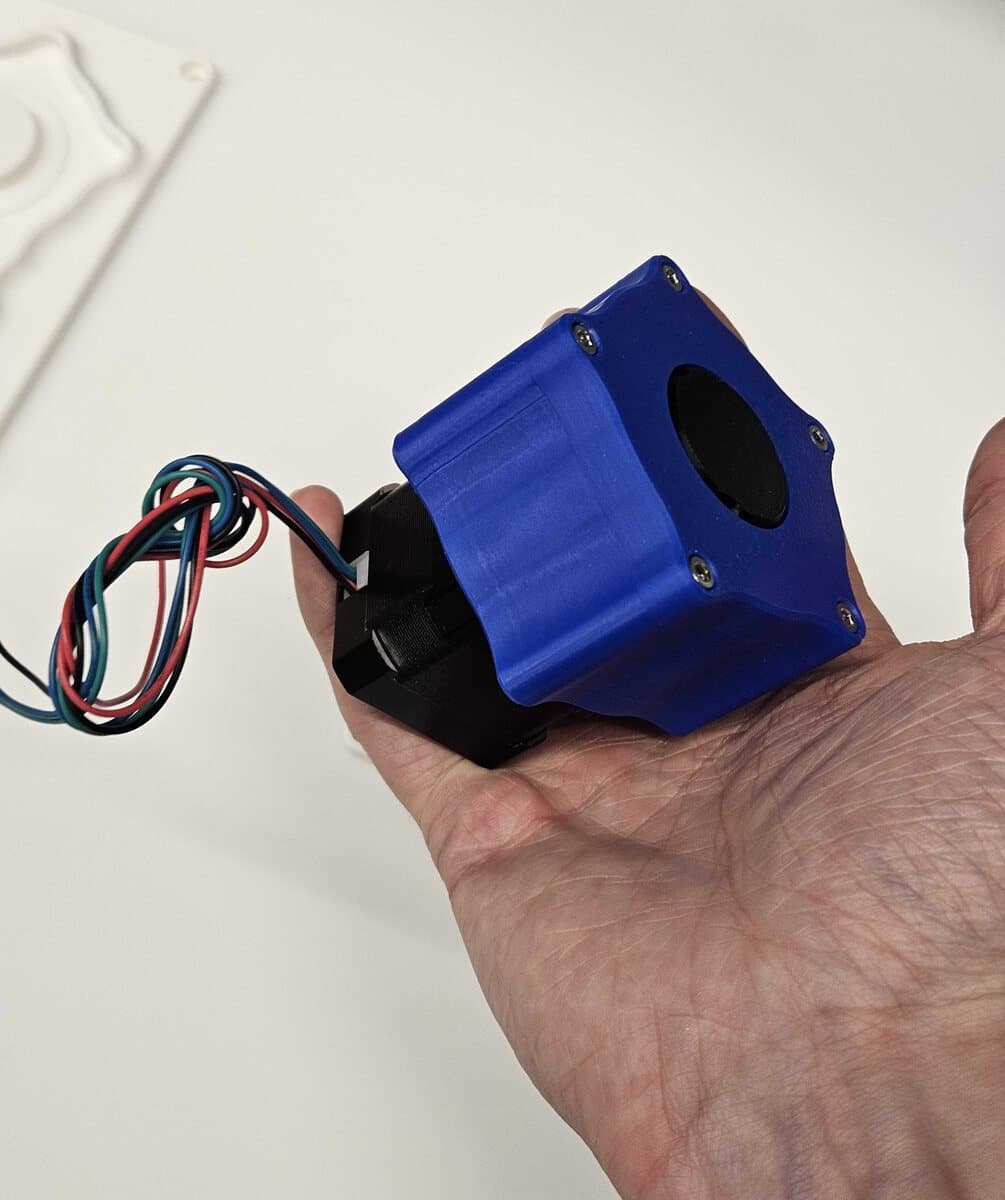
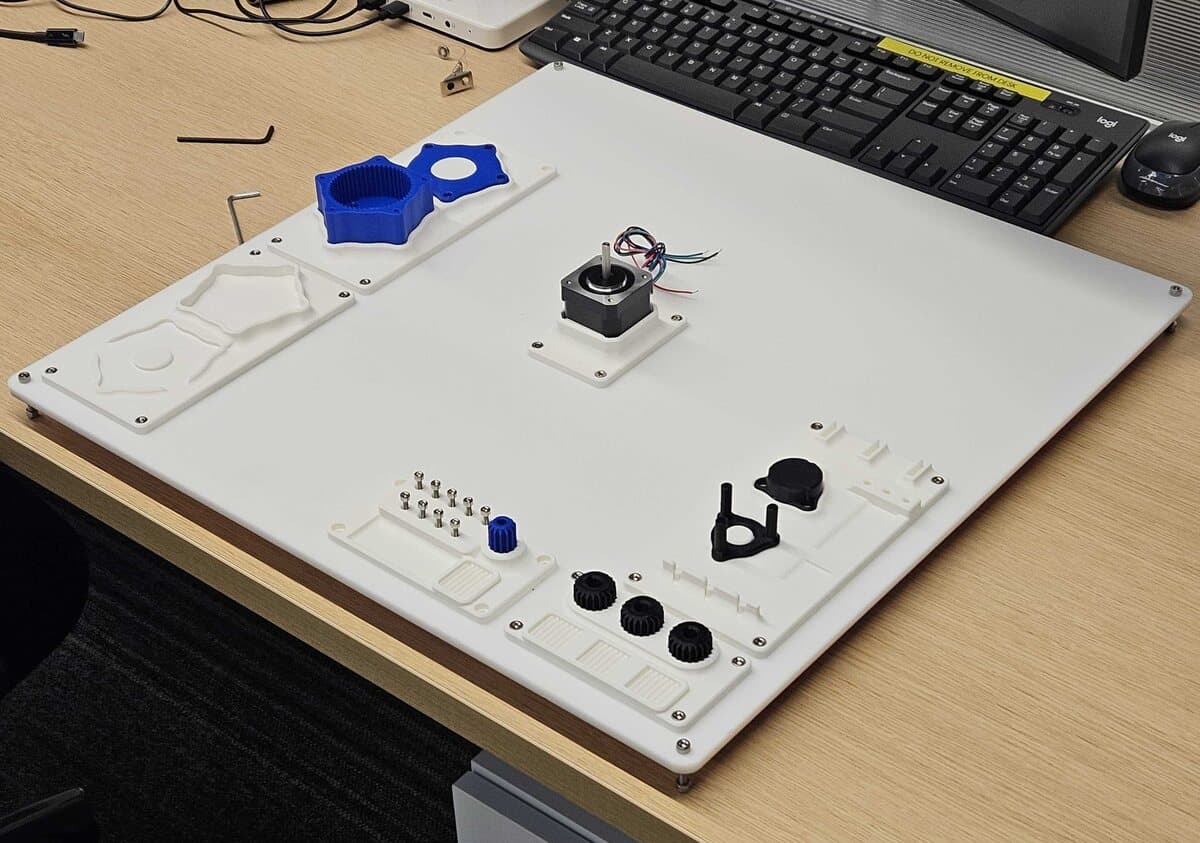
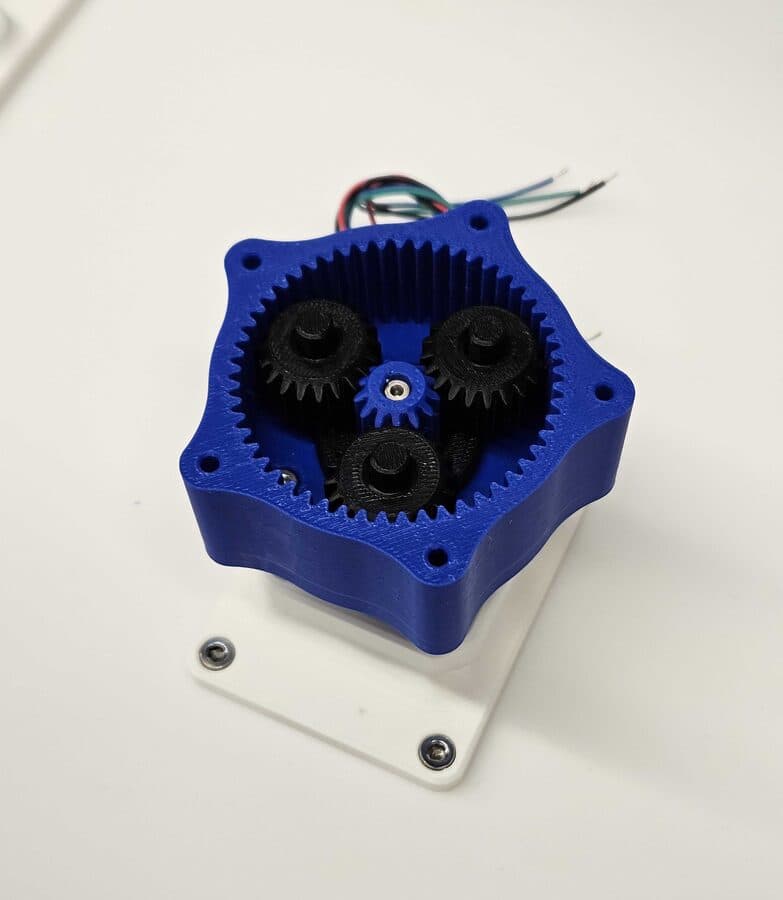
Three low-cost, reproducible boards — datacenter fiber switches, automotive harnesses, and a planetary gearbox — built in the NIST Assembly Task Board tradition. | A ROS 2 framework tying together teleoperation, time-aligned multi-sensor capture, and real-time impedance control for rapid data collection and deployment. | A diffusion policy fusing wrist & scene RGB, point clouds, and proprioception with per-phase input gating, chained by a behavior tree at deployment. Adapted from Improved 3D Diffusion Policy (iDP3). |
Tags
Comments
Join the conversation at EngineerZone
Opinions expressed in the content posted here are the personal opinions of the original authors, and do not necessarily reflect those of Analog Devices, Inc (ADI) or its subsidiaries. The content is provided for informational purposes only and is not meant to be an endorsement or representation by ADI or any other party. This site may also provide links or references to non-ADI sites and resources. ADI makes no representations, warranties, or other commitments whatsoever about any non-ADI sites or third-party resources that may be referenced, accessible from, or linked to this site.